Explorar las categorías
Español
$
USD
Conéctate con tu IA
Robotics and Embedded Systems Engineer, ROS 2, Computer Vision, Sensor Fusion
Habilidades
Revisa mis servicios

Freelance Robotics & Embedded Engineer
Upwork • Freelance
Nov 2025 - Present • 1 yr
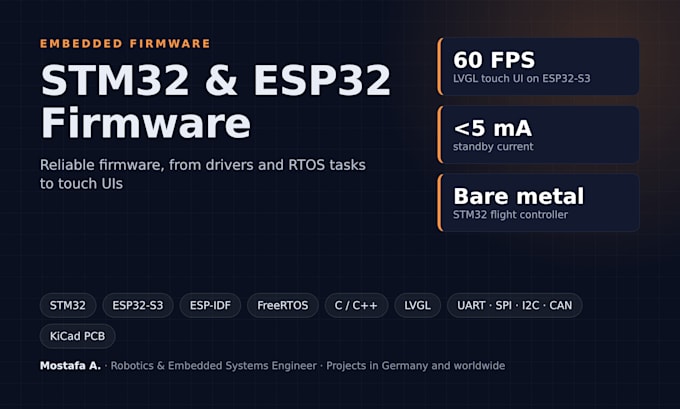
Remote robotics and embedded contracts for clients worldwide. - RTK GNSS localization and waypoint navigation for an outdoor rover (ROS 2, Jetson): 50 Hz EKF, 3 mm repeatability at rest, validated with a hardware-in-the-loop simulator - 15-state EKF library in C++ that fuses phone GNSS and IMU into vehicle motion at 234 Hz, with 0.4 degree median heading error - Four-drone formation flight on ROS 2 with PX4 SITL and MPC planning, holding formation in 5 m/s wind - UV-C disinfection robot autonomy in ROS 2 Jazzy with Nav2 and slam_toolbox, 262 passing tests - ESP32-S3 touch-display firmware with LVGL at 60 FPS and under 5 mA standby - Photogrammetry pipeline that turns 85 phone photos into a web-ready 3D model
Robotics & AI Working Student
Lucas Nülle • Tiempo parcial
May 2026 - Aug 2026 • 3 mos
Product Management Energy & Industry (Kerpen, near Cologne). - Commissioned a ROS 2 Humble robot arm platform on an NVIDIA Jetson Orin Nano: depth-camera 3D scanning into RViz, a two-way MoveIt 2 digital twin, GPU object detection with autonomous sorting, and a PyQt5/Blockly teaching app - Built an ArduPilot SITL drone training environment (quadcopter, fixed-wing, flying-wing and VTOL) with Webots and AirSim, georeferenced terrain from a self-written local WMS server, and 20 reproducible fault-injection scenarios, packaged for offline school PCs

Embedded Systems Intern
Valeo • Tiempo completo
Jul 2025 - Sep 2025 • 2 mos
System testing for embedded automotive software projects at Valeo Cairo. Built an automated test-management tool that raised the team's testing throughput by over 200%.
