Explorar las categorías
Explora
Fiverr Pro
Español
$
USD

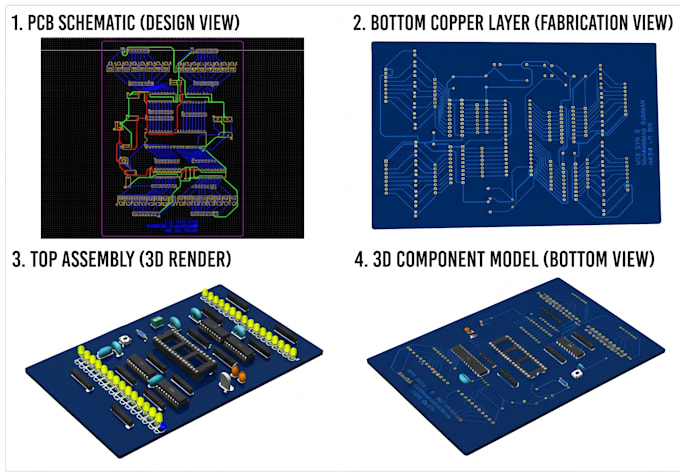
PCB Design, ROS2
Habilidades
Revisa mis servicios
Robotics Intern
National University of Sciences and Technology (NUST) • Tiempo parcial
May 2026 - Aug 2026 • 3 mos
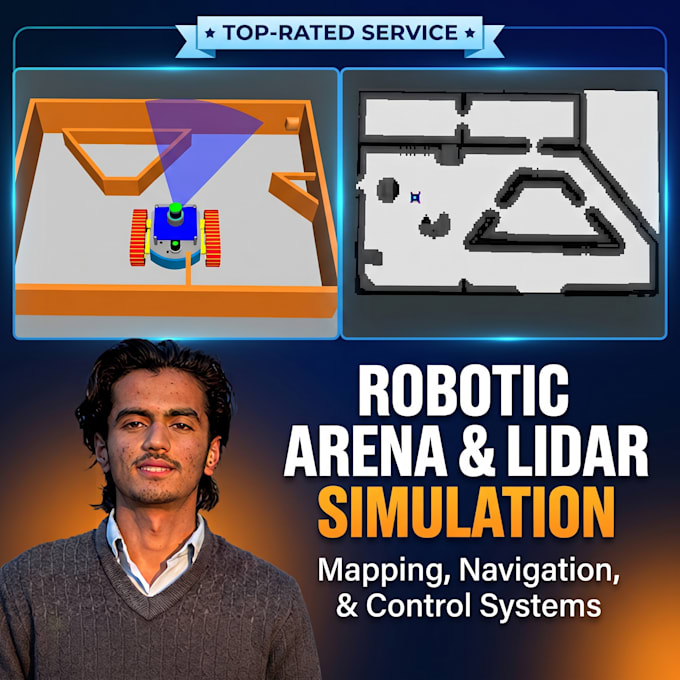
Designed, built, and deployed a four-wheel holonomic mobile robot in ROS2/Gazebo from the ground up, without using premade robot models or default configurations.. I did this under my 3 months work at Industrial AI and IoT lab at College of EME, National University of Sciences and Technology. Modeled custom mecanum wheel geometry in SolidWorks and converted it into individual STL meshes (8 rollers + hub per wheel) with physically accurate Gazebo friction properties Configured Nav2's MPPI controller for true omnidirectional motion, correctly tuning the motion model and critic weights for holonomic kinematics — a nonstandard configuration most Nav2 setups don't handle Implemented sensor fusion (wheel odometry + IMU) via robot_localization to reduce drift from roller slip Built a custom Python-based coverage path planner (boustrophedon pattern) for autonomous full-area sweep navigation Diagnosed and resolved non-obvious ROS2 topic remapping and controller lifecycle issues independently
